
Equivariant Visual-Tactile Diffusion Policy for Contact-Rich Manipulation
Published in Conference on Robot Learning (CoRL 2026), 2026
Accepted to the Conference on Robot Learning (CoRL 2026).
Project Page · Main Code · Robot Code · Dataset
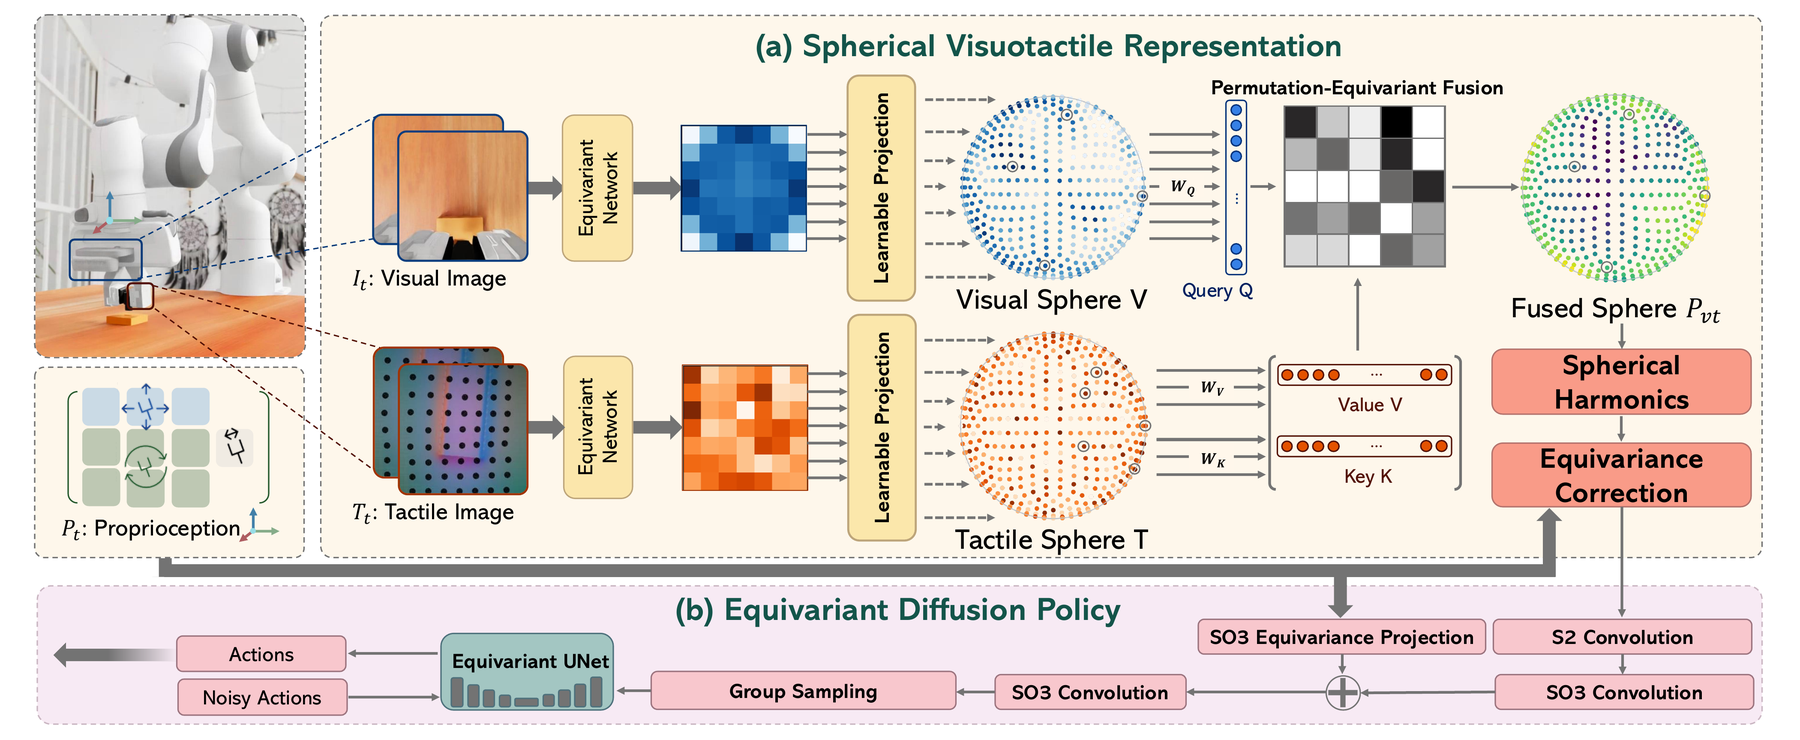
VISTA projects visual and tactile observations into spherical tokens, fuses contact cues with visual directions while preserving geometric structure, and conditions an equivariant diffusion policy to predict spatially consistent actions.
BibTeX Citation
@inproceedings{wong2026vista,
  title={Equivariant Visual-Tactile Diffusion Policy for Contact-Rich Manipulation},
  author={Wong, Lik Hang Kenny and Ma, Yiyao and Wei, Xiu-Shen and Tan, Zelong and Song, Zhuheng and Xie, Dongsheng and Chen, Kai and Dou, Qi},
  booktitle={Conference on Robot Learning},
  year={2026}
}